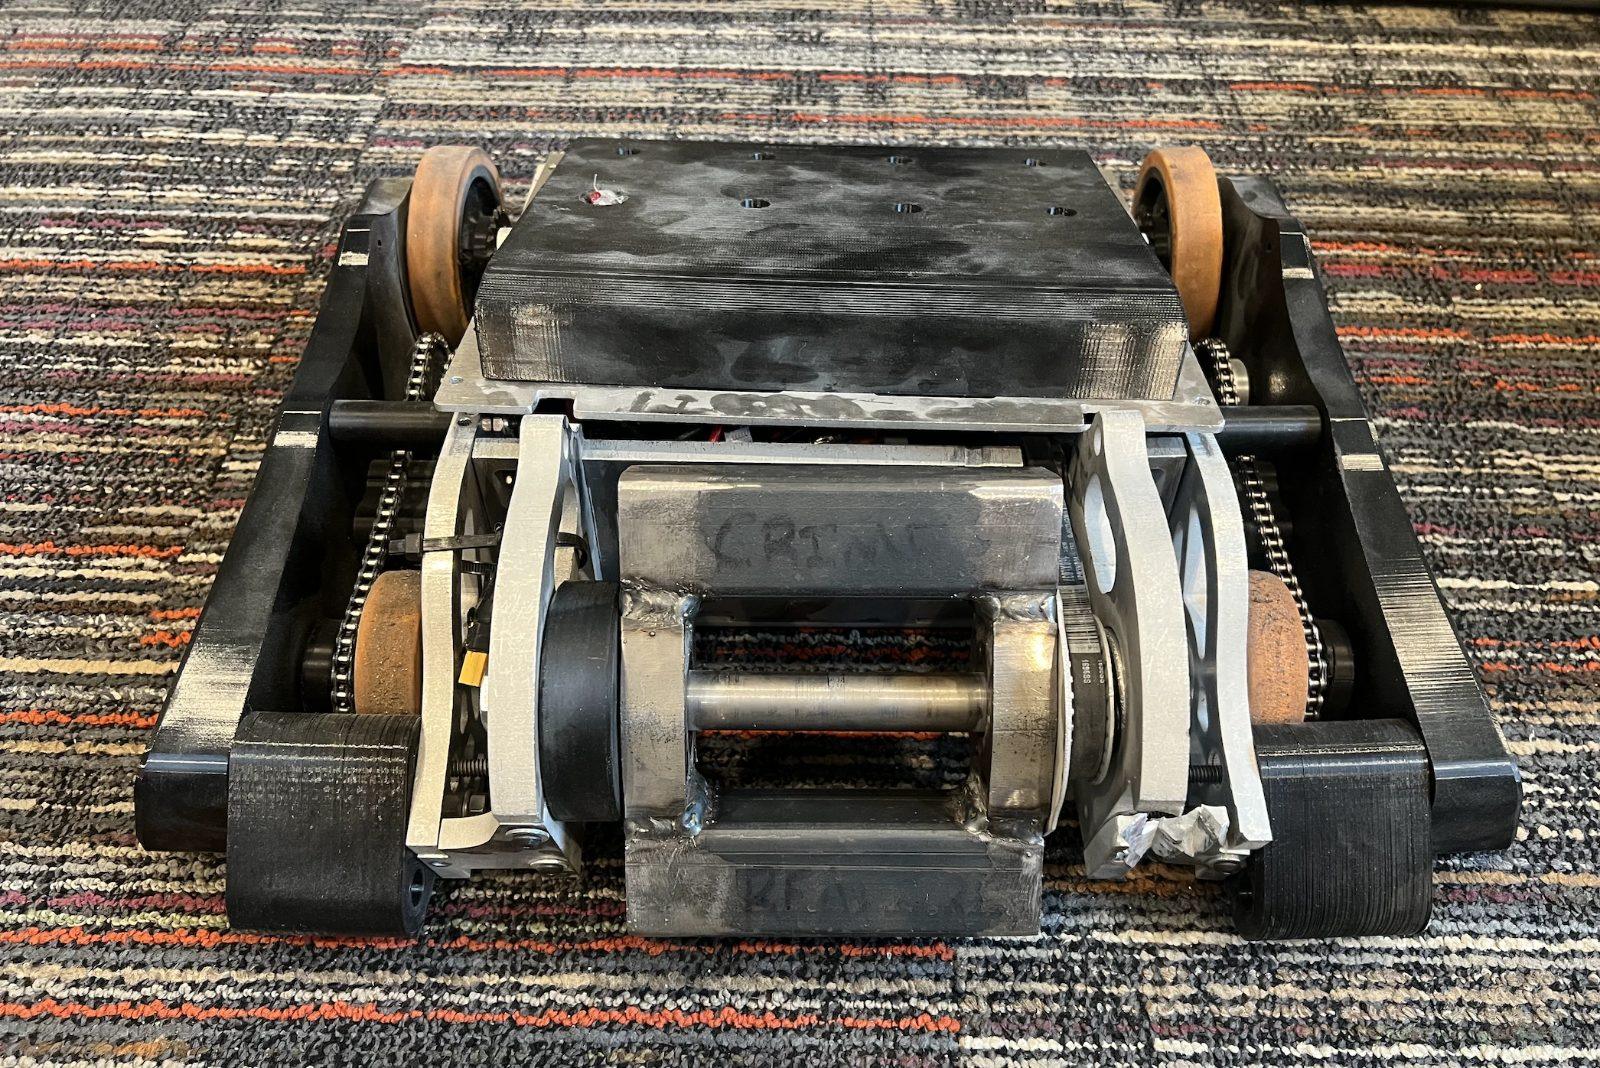
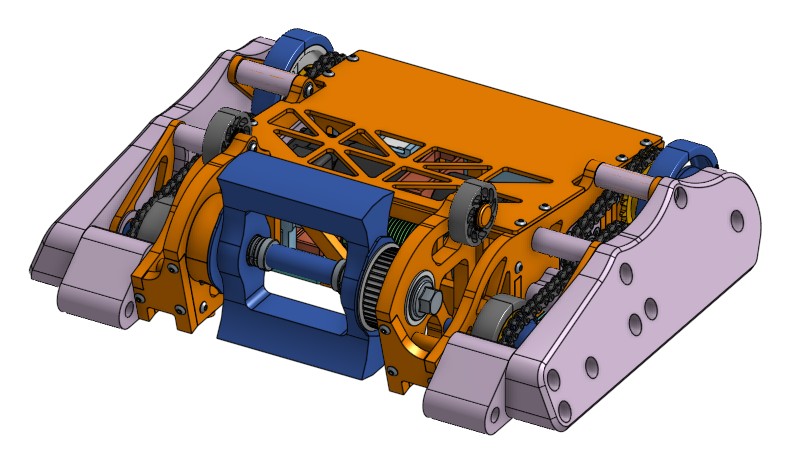
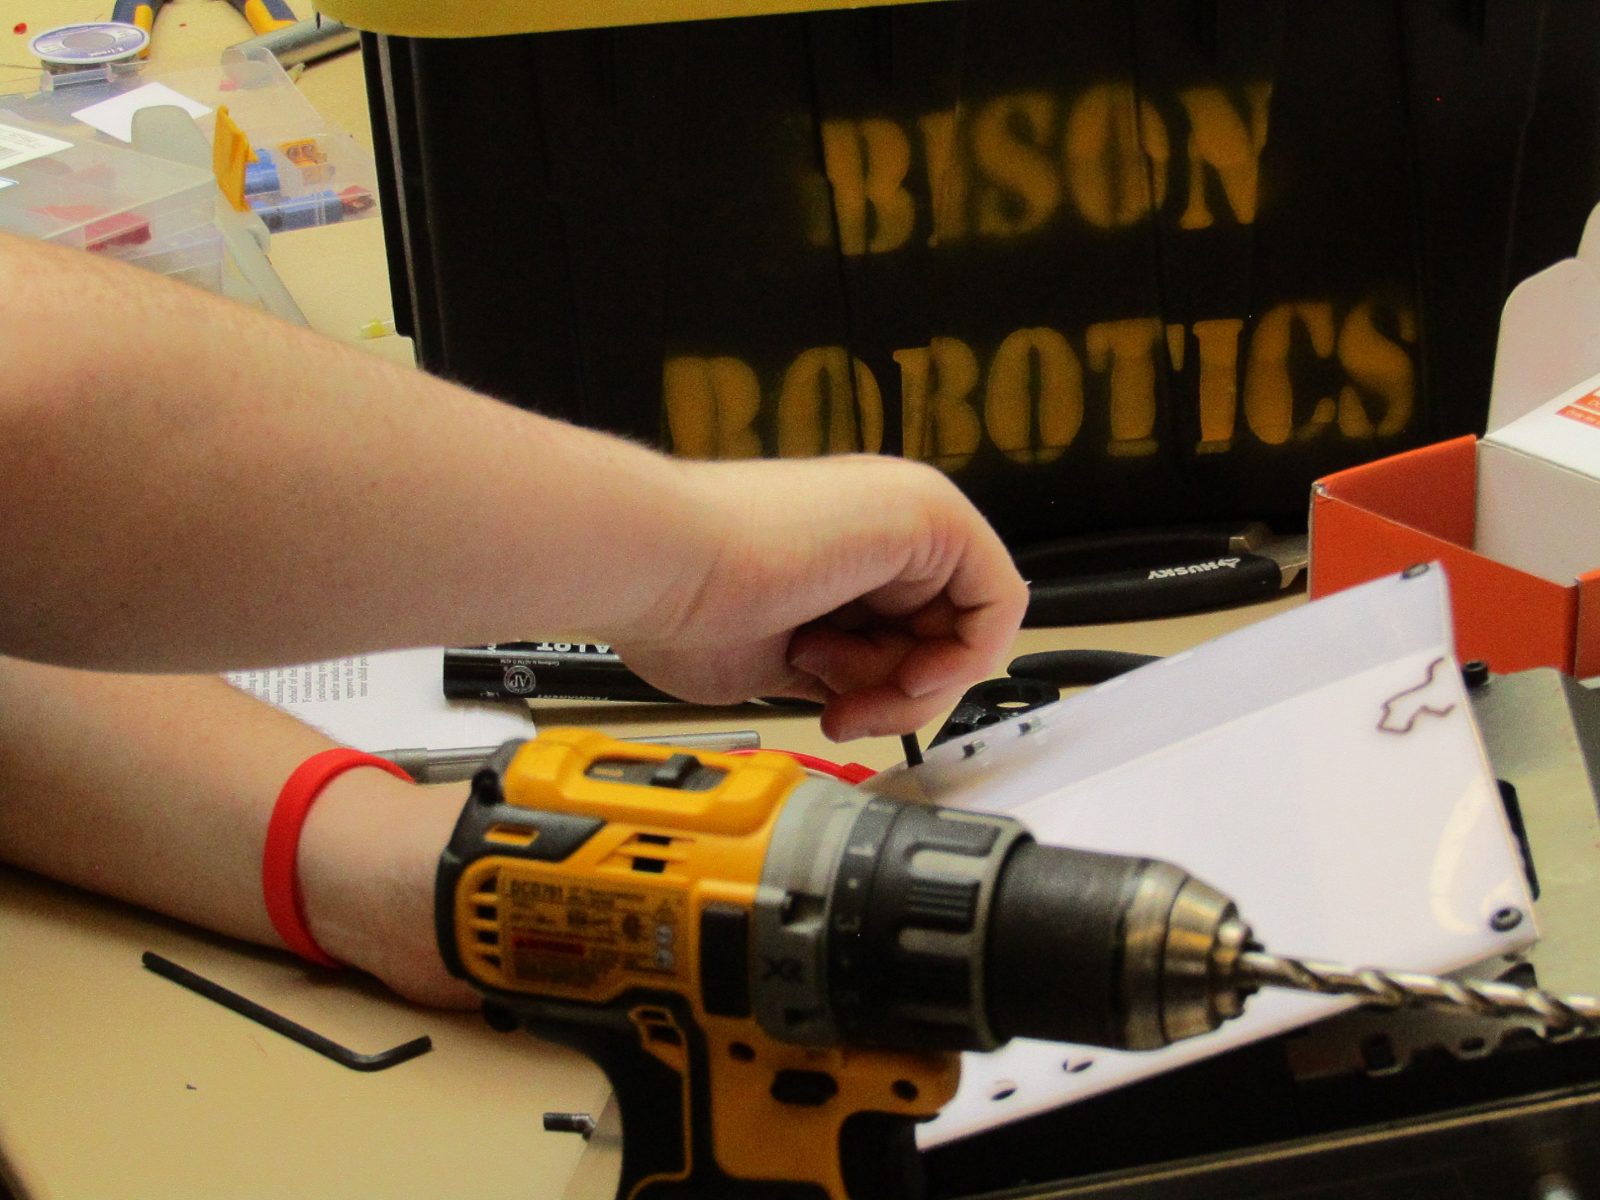
Team lead, 4 people · Bison Robotics · 30 lb · UIUC Robobrawl XI
Second-generation combat robot. I took over as captain halfway through development and led
design reviews, CAD, fabrication, and competition prep; every major decision traced back to a
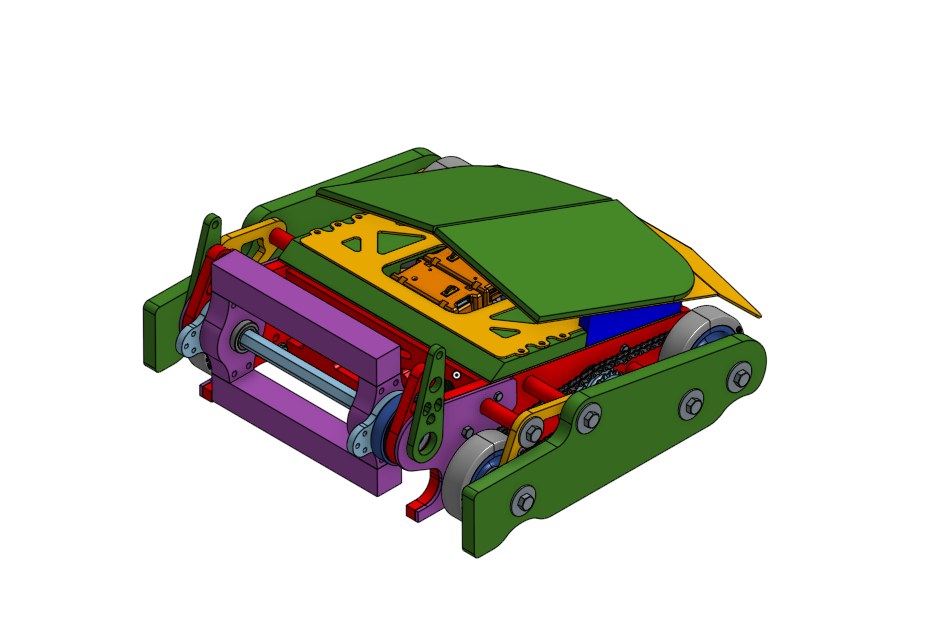
documented failure mode from Cowbot. High-RPM horizontal beater bar, chain-driven 4WD on
brushless motors, and an aluminum truss frame between machined side rails, with the weight
budget managed in CAD.
Competition-ready chassis.Full chassis CAD.
Cowbot
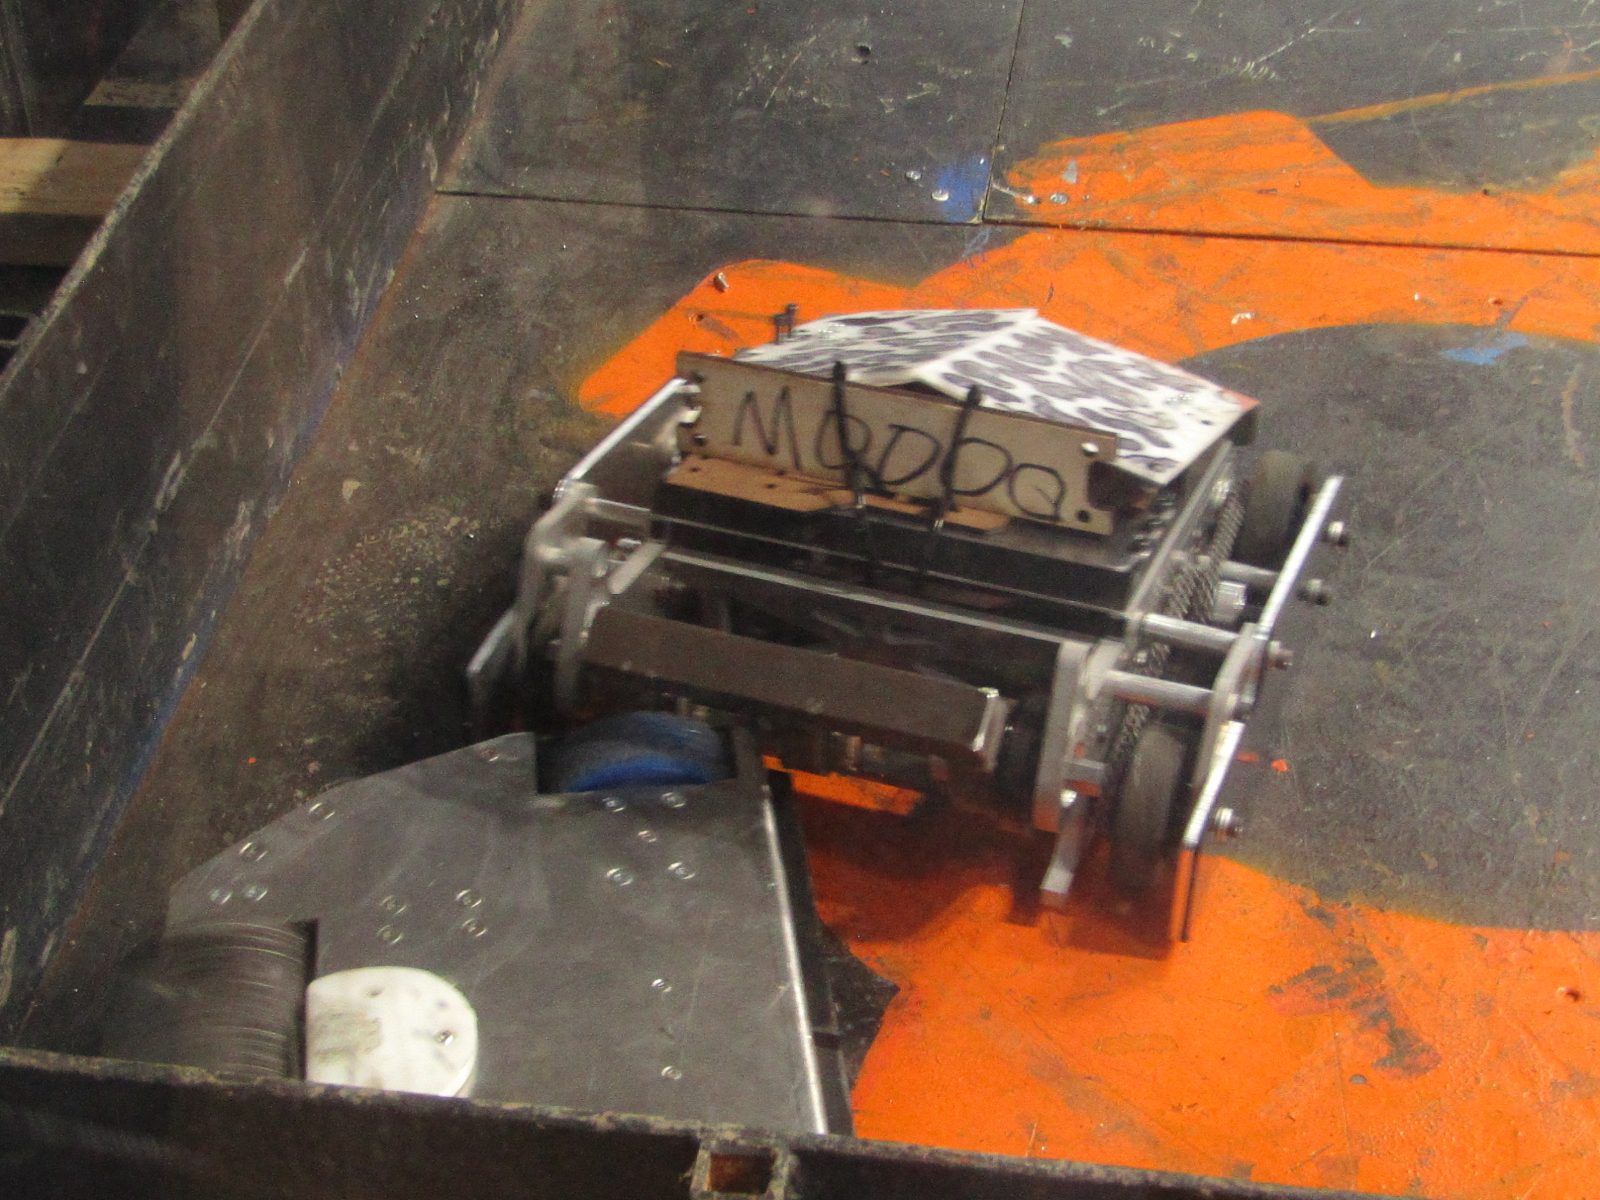
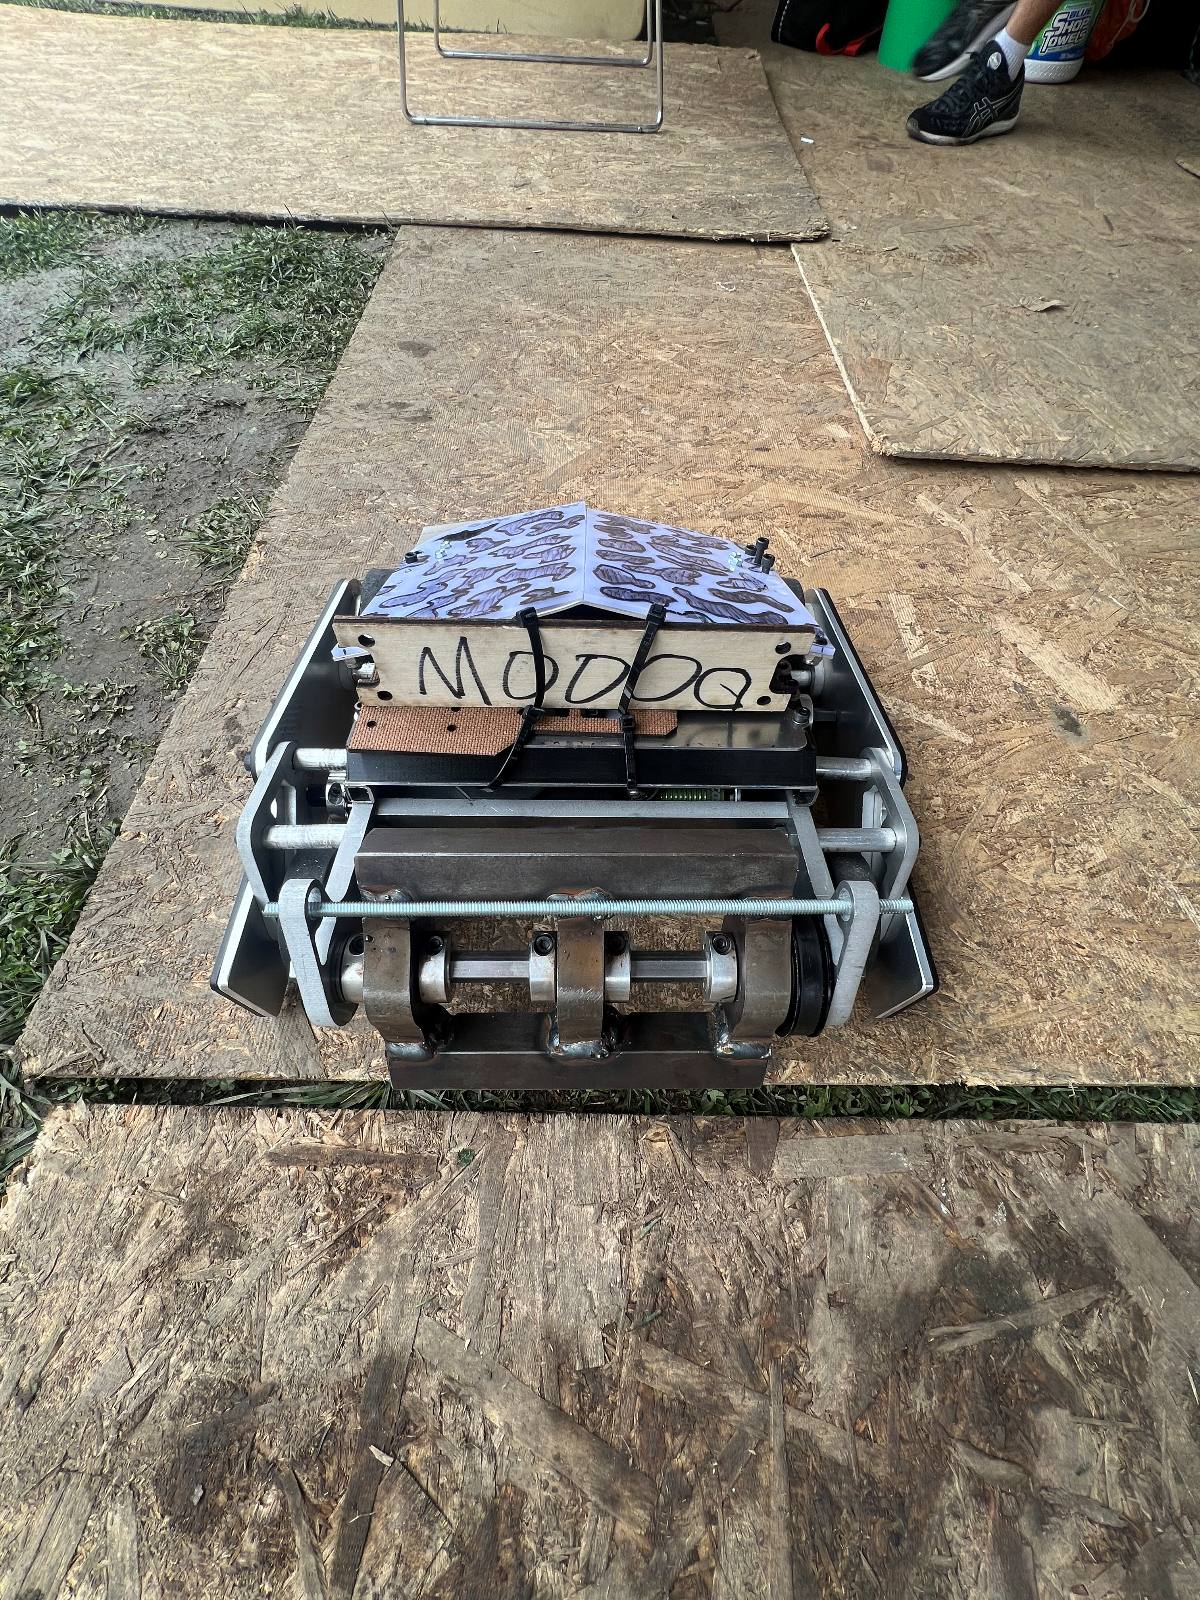
Contributor, 5 people · Bison Robotics · 30 lb · UIUC Robobrawl X
My first combat robot, from concept to competition day. I worked on wheel placement,
motor-mount geometry, and the structural framing for the drivetrain, and helped fabricate the
weapon. Its failure modes at competition became the design brief for Boulderbot.
Robobrawl X.Before a match.In the shop.CAD.
3D Gaussian Splatting under lunar lighting
Research intern · NASA JPL · Jun – Aug 2026 · Python, 3DGS
Near the lunar poles the sun sits a few degrees above the horizon, lighting terrain with long,
hard shadows. I ran ordered image sequences of a lunar surface through a 3DGS pipeline, swept
the lighting conditions that matter most at the poles, and quantified where reconstruction
quality breaks down and how, to inform perception for rover path planning.
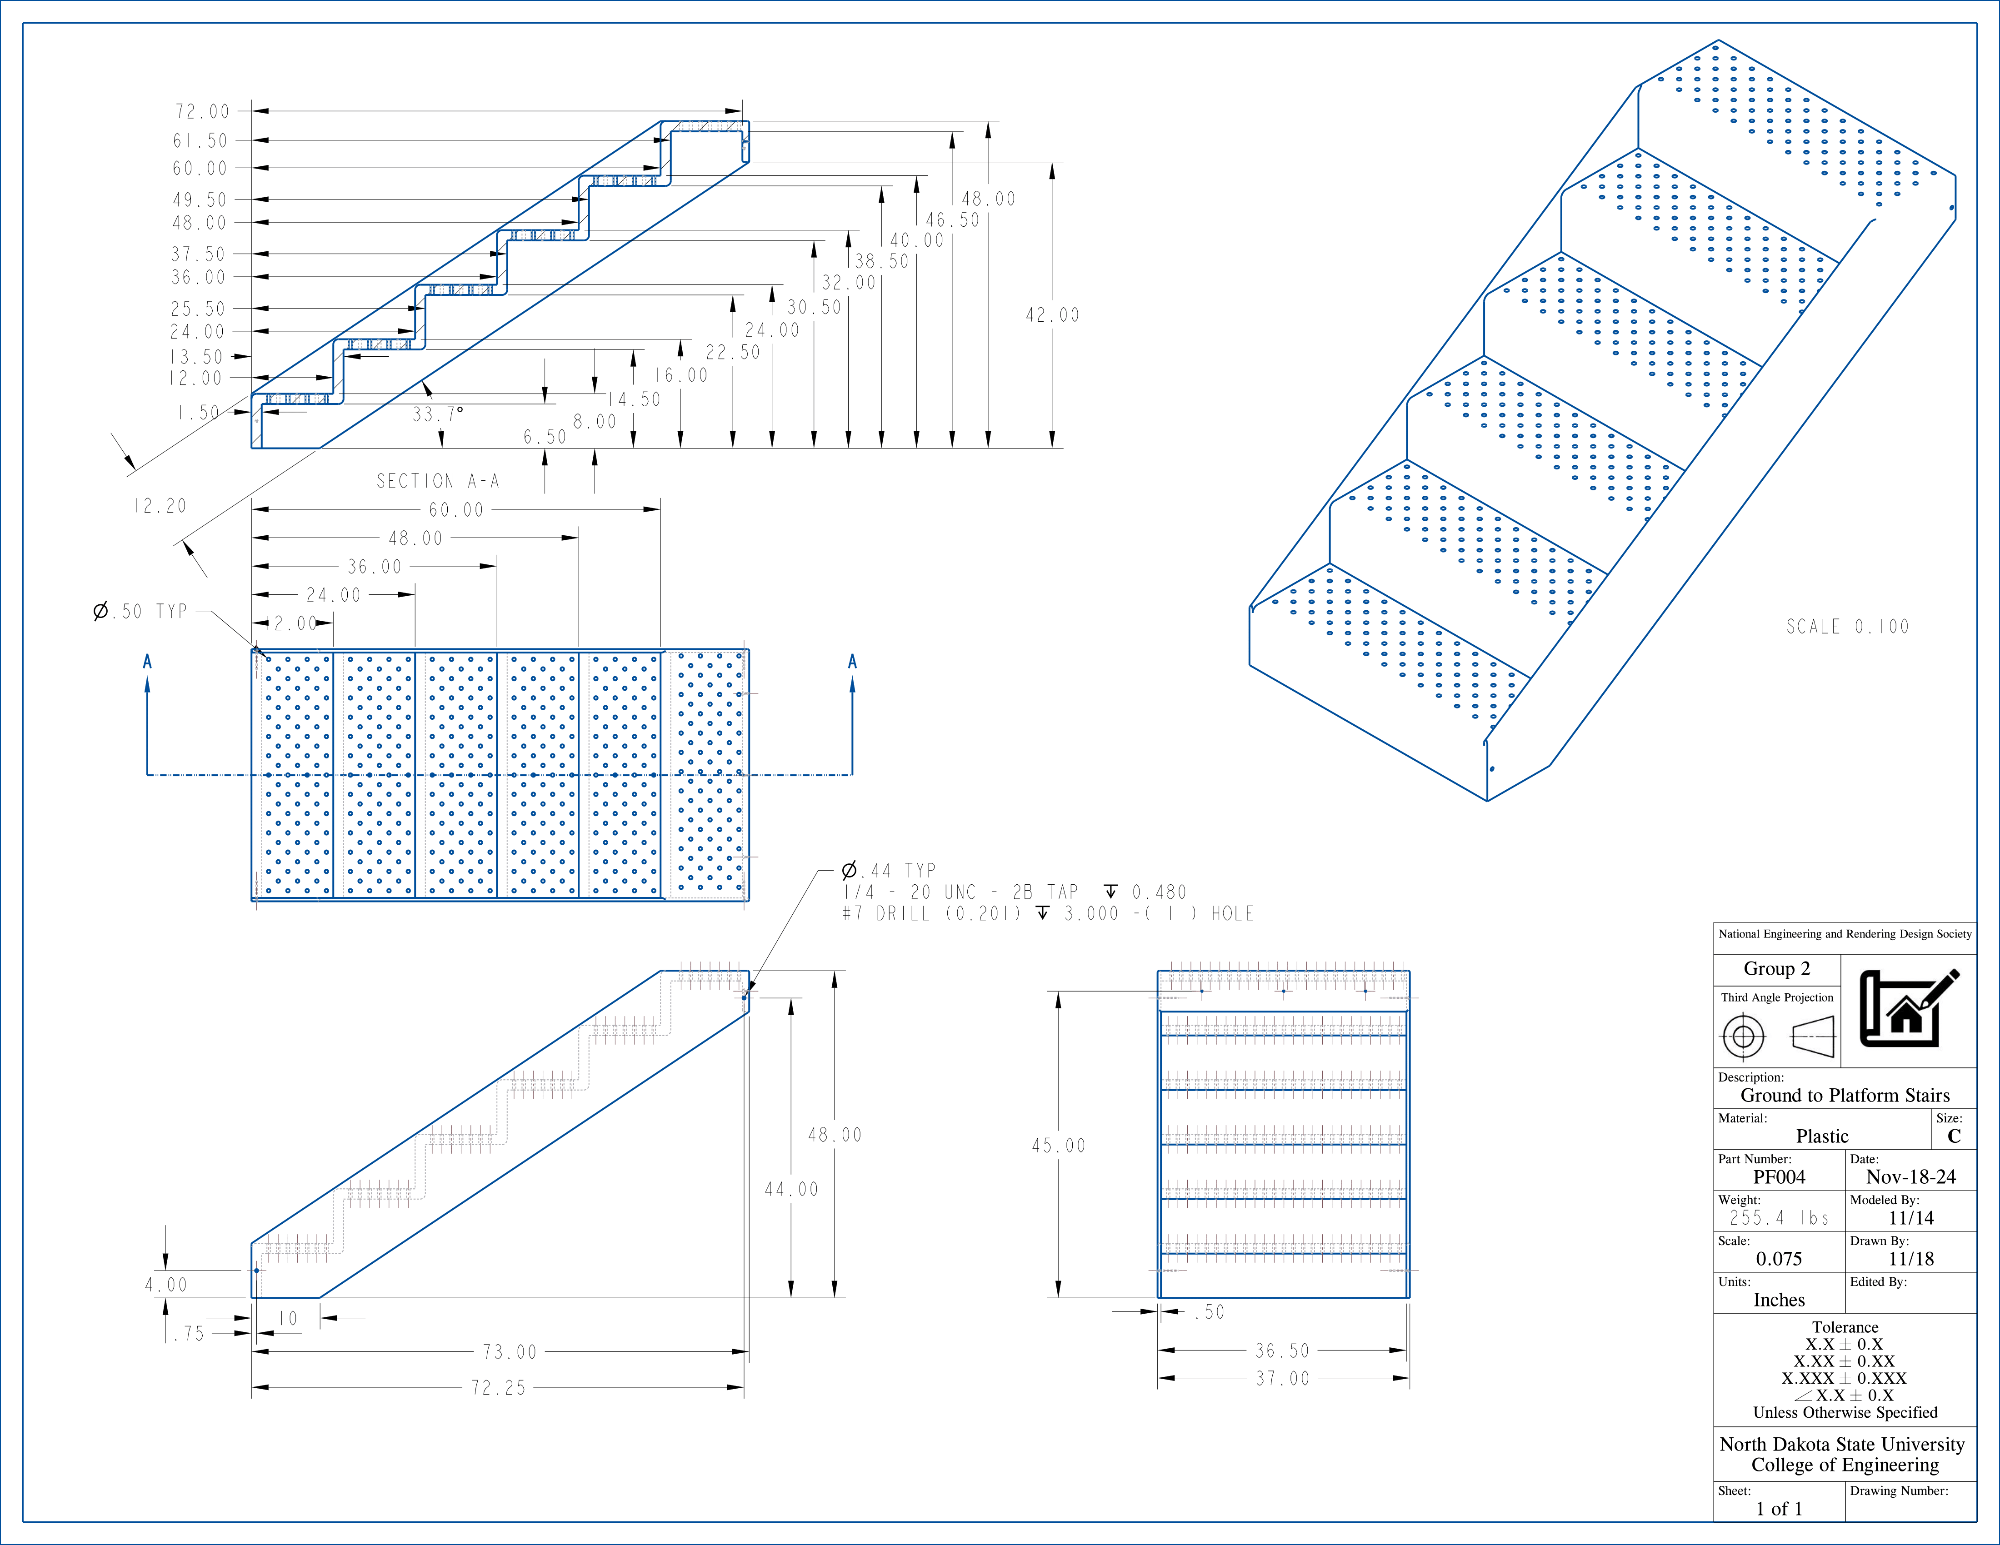
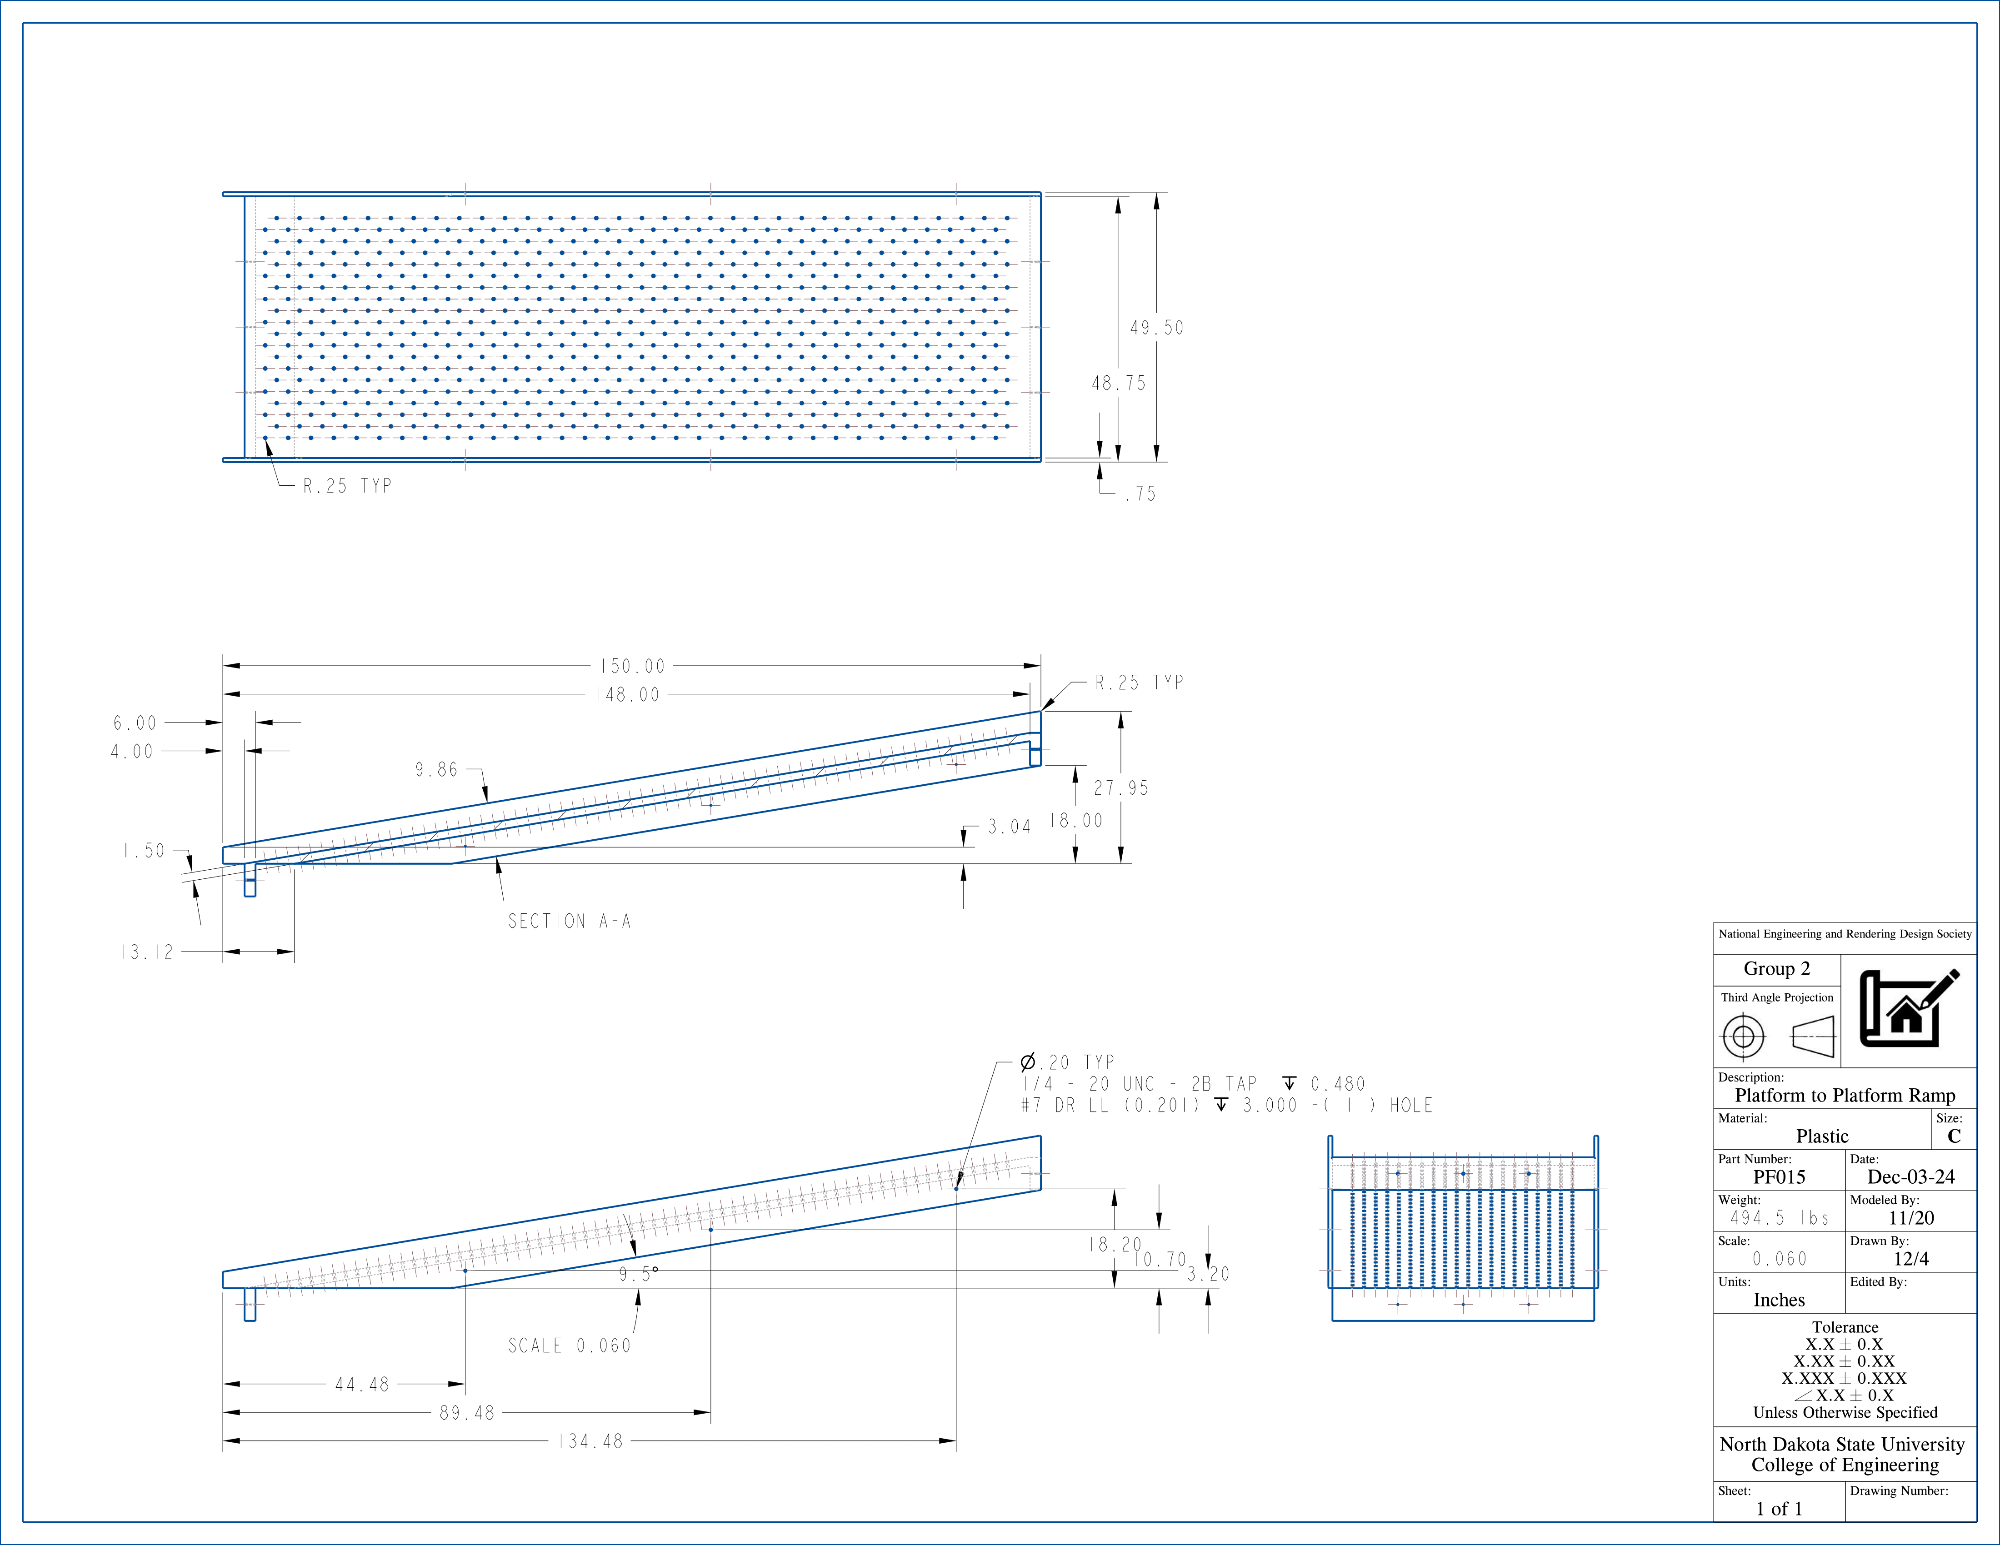
Playground design package
Team lead, 4 students · ME 212 Visual Communication for Engineers
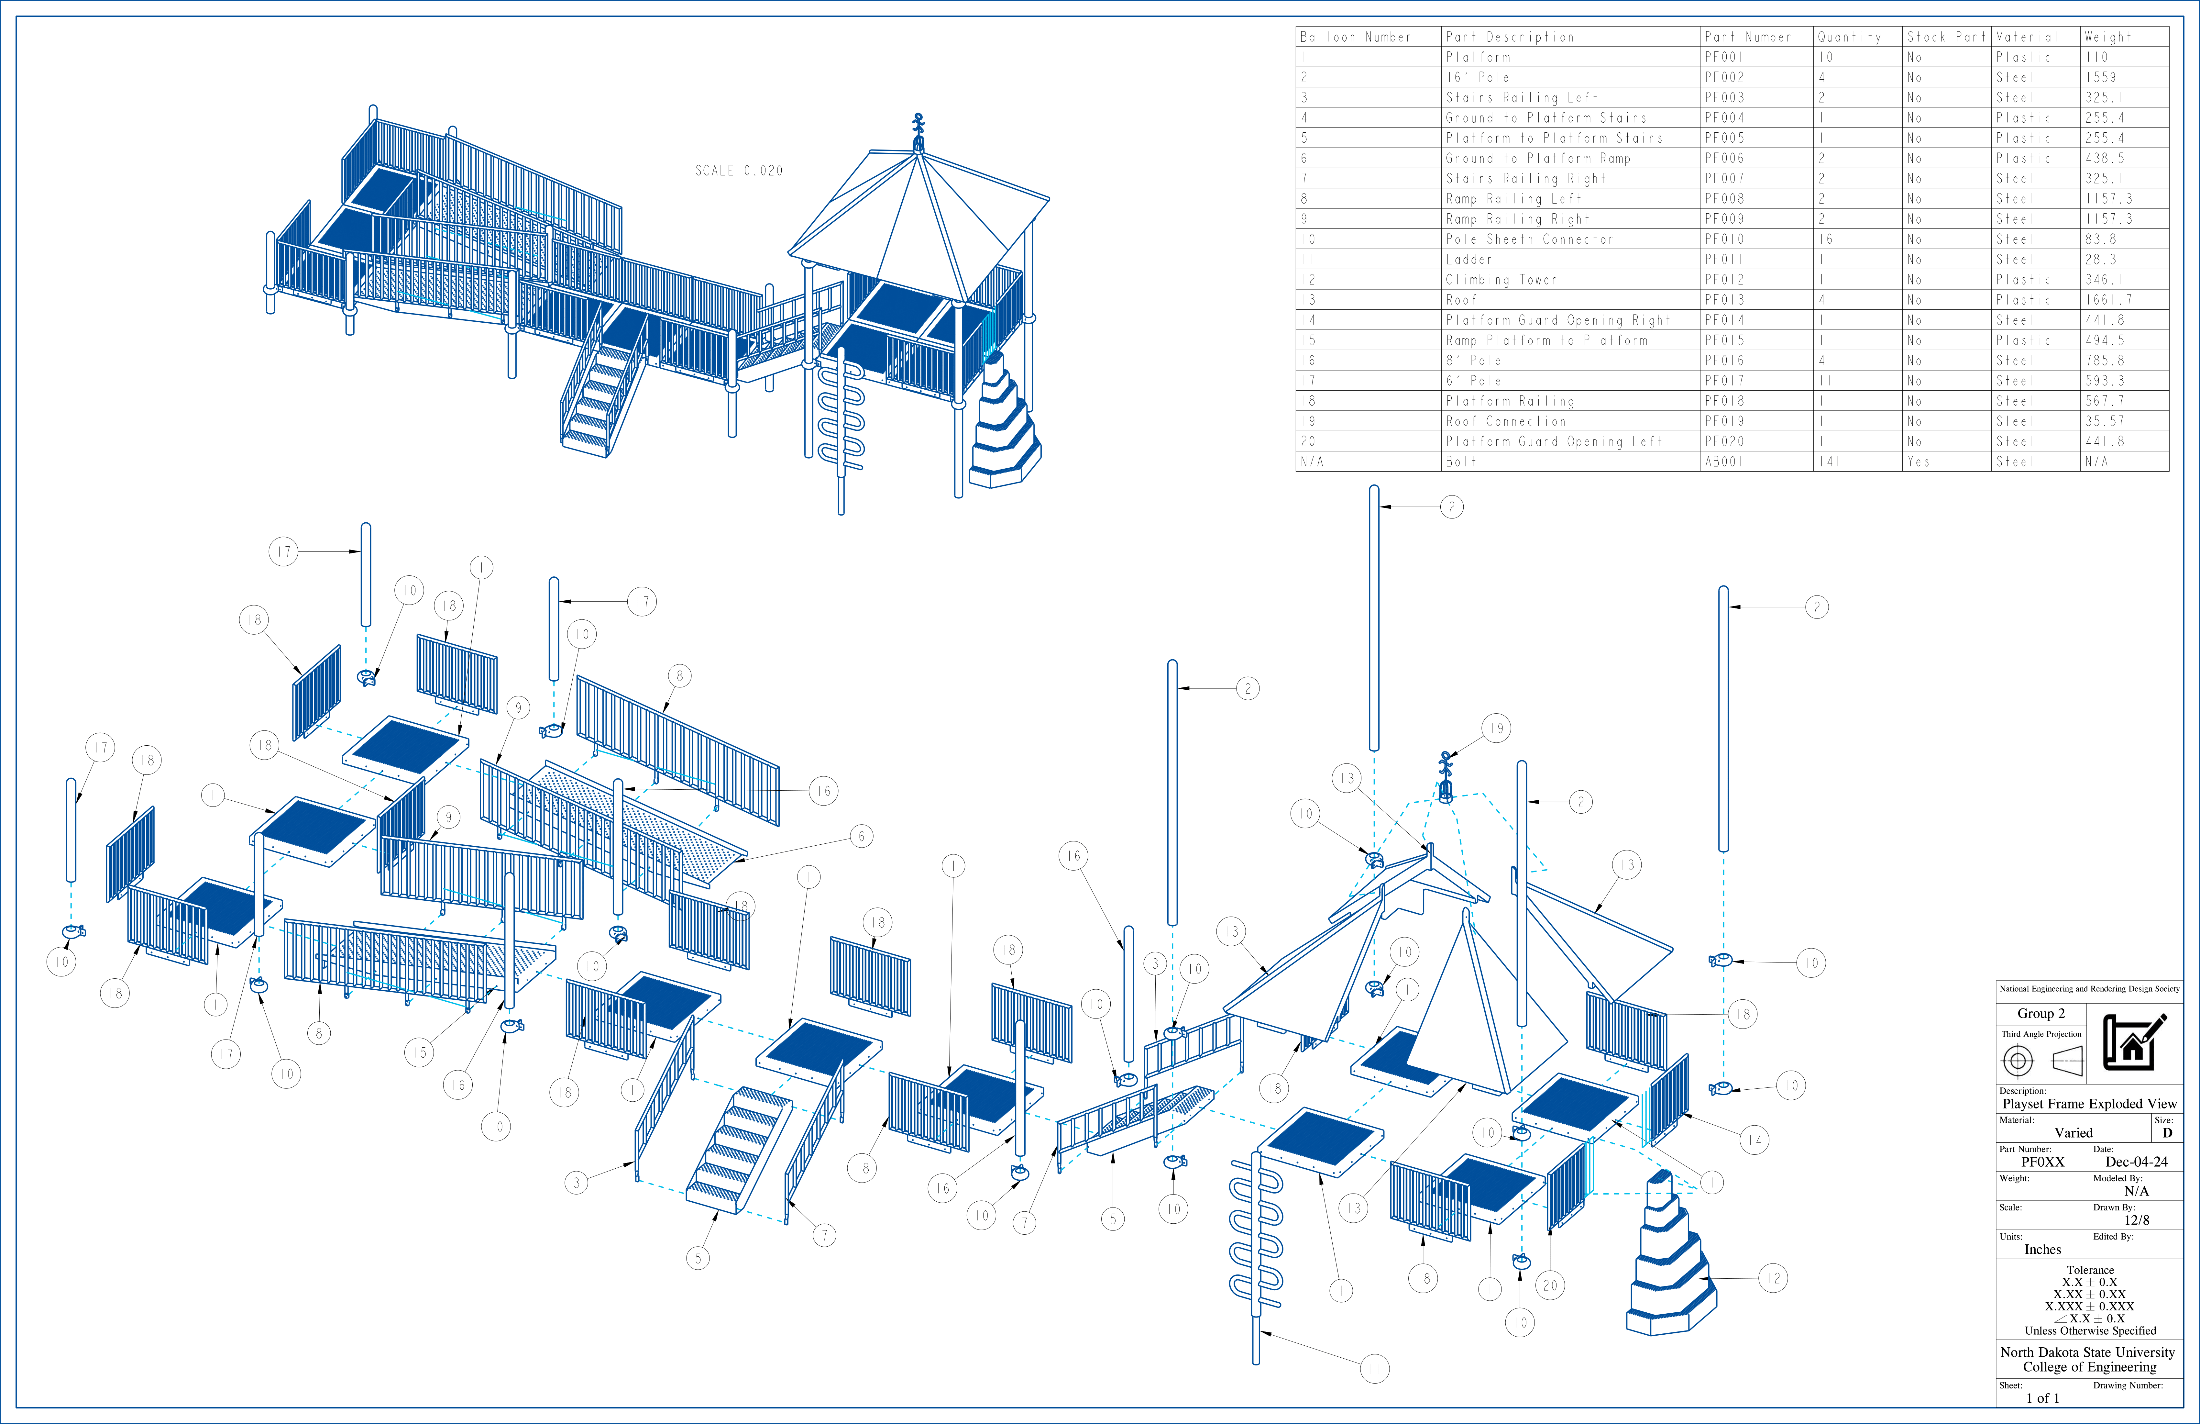
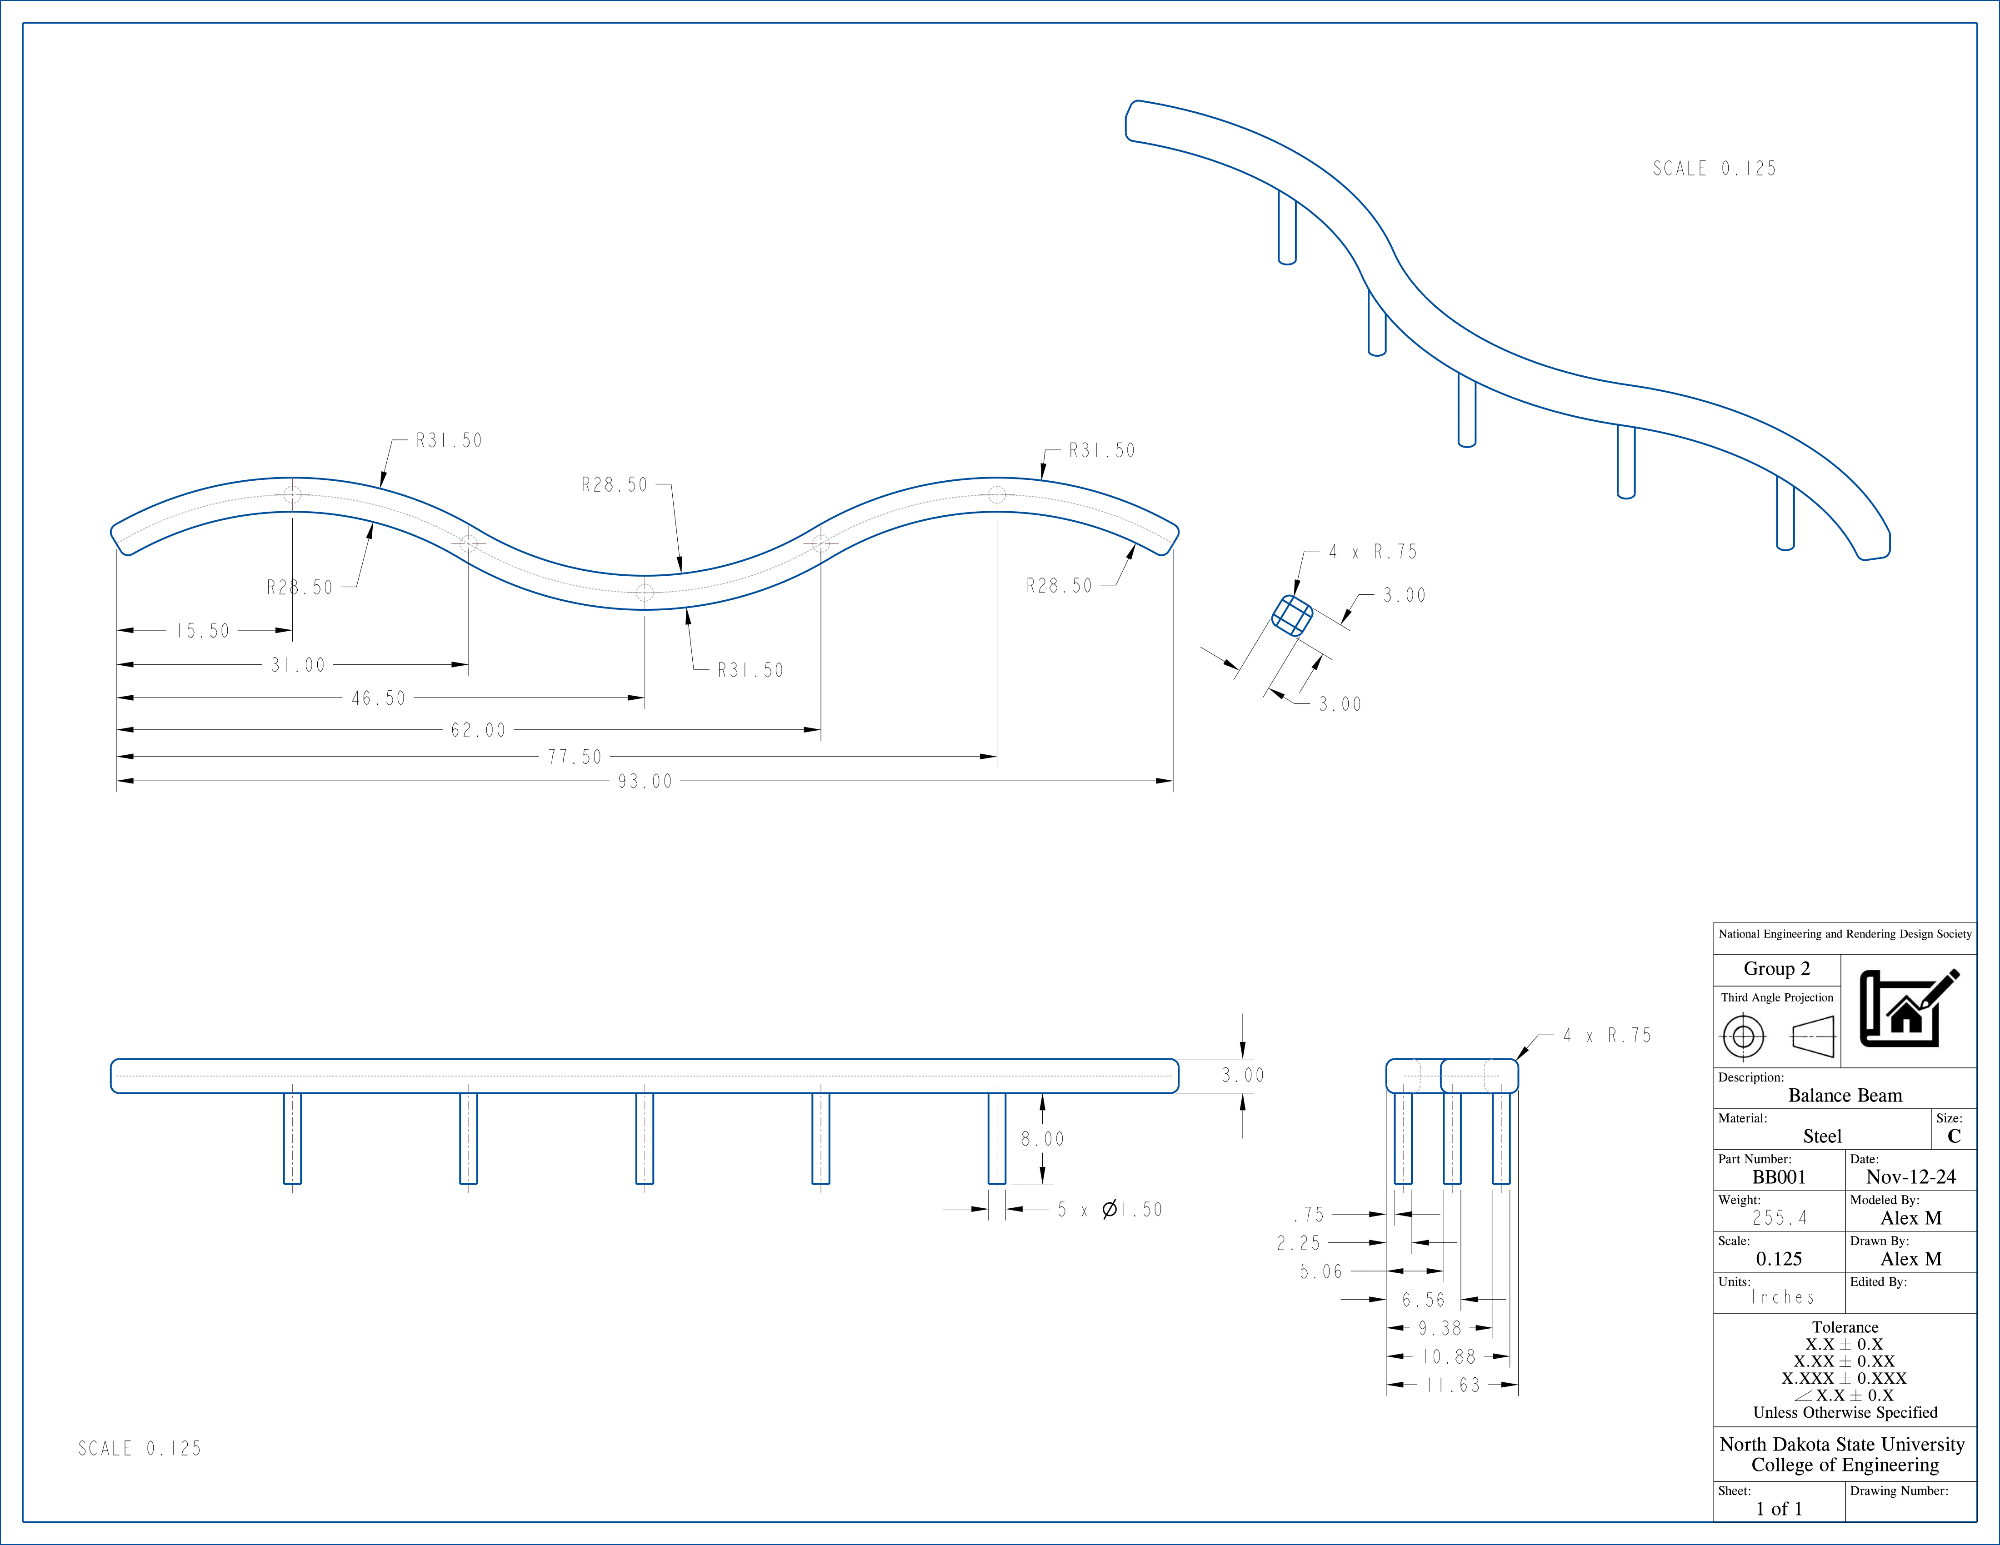
Site analysis, safety compliance, and a full drawing package for a playground in Fargo: an
exploded view with a parts list, plus dimensioned and toleranced detail drawings for each part.
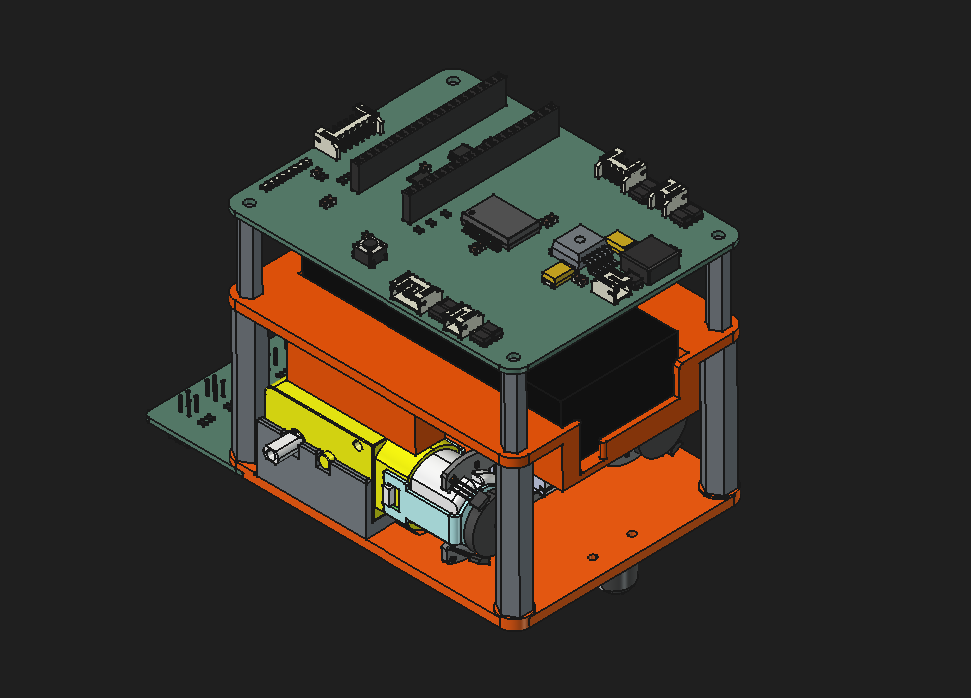
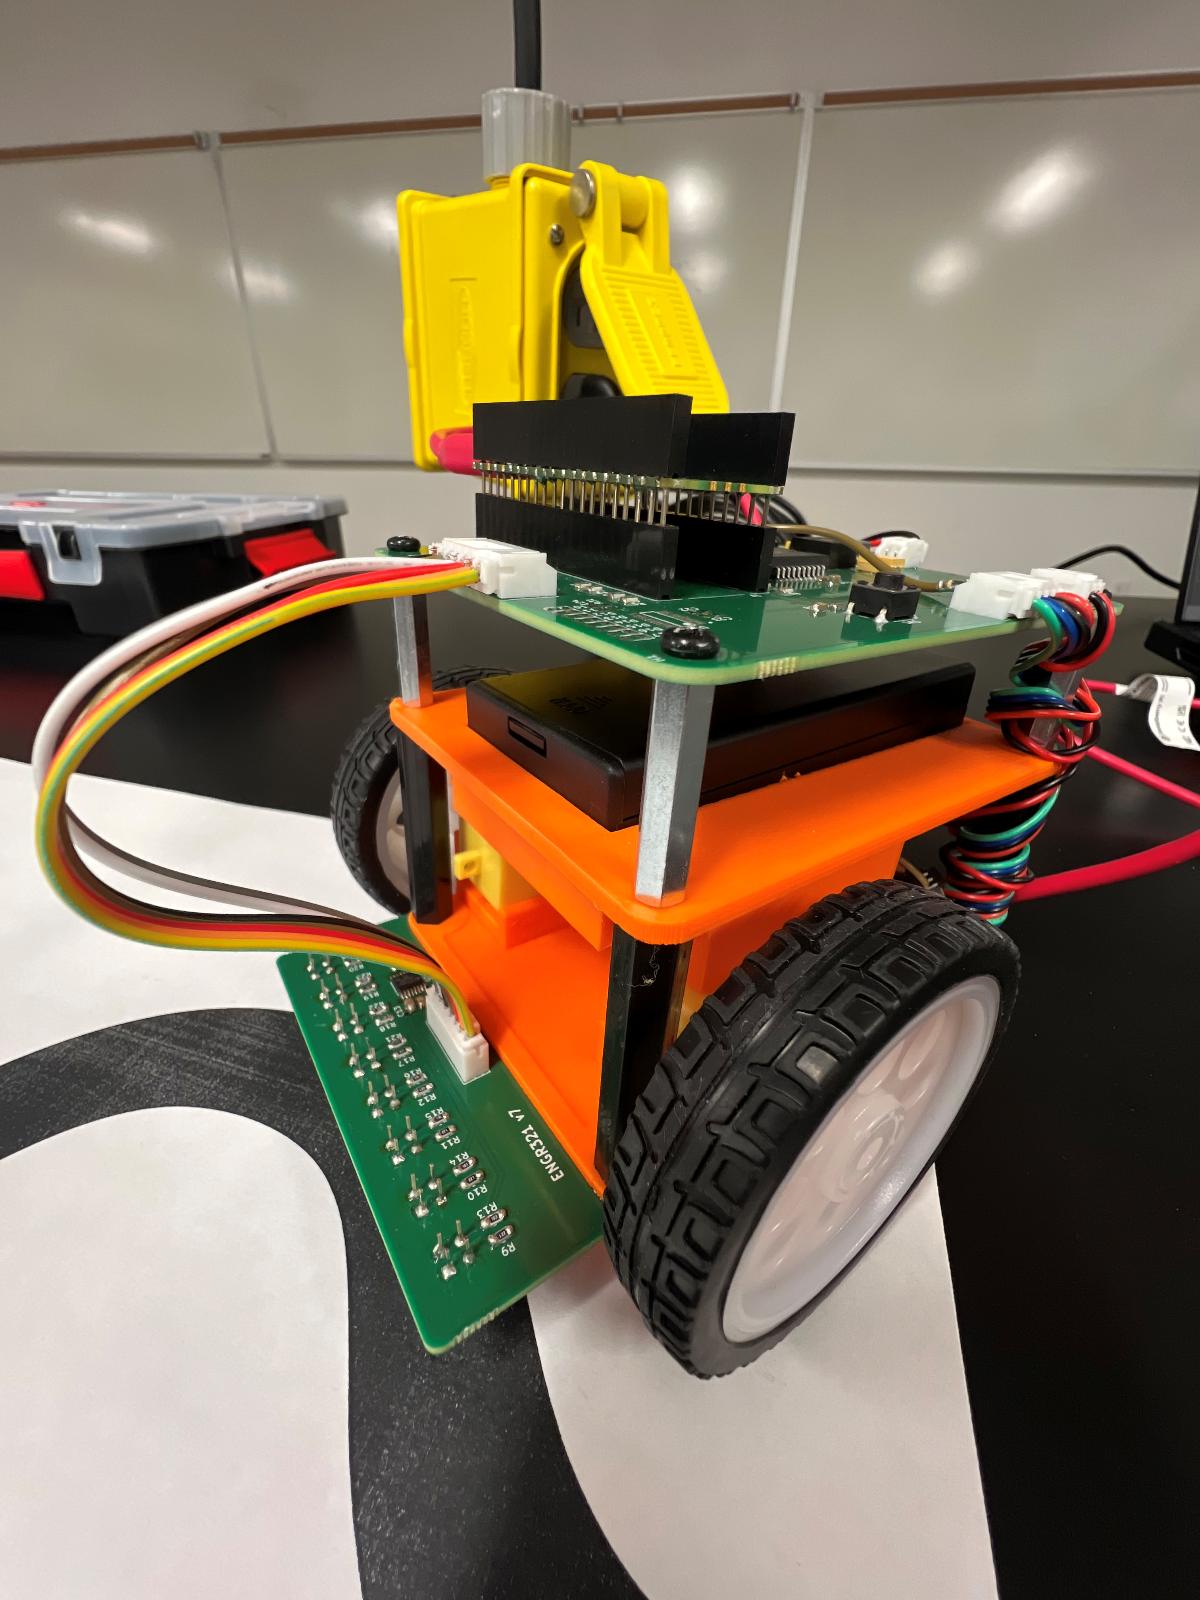
Team member, 5 students · ENGR 321 Introduction to Robotics
Assembled a two-tier kit chassis, integrated a reflectance sensor array, and wrote the
line-following controller in Python with a PID loop on the sensor error.
Chassis CAD.As built.
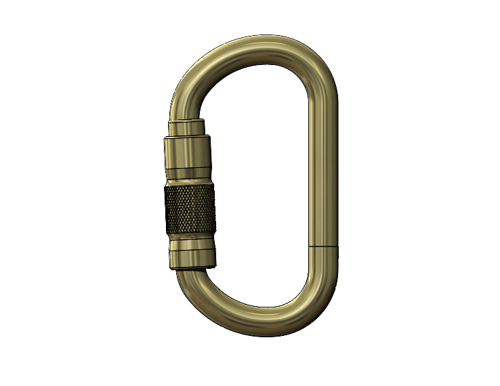
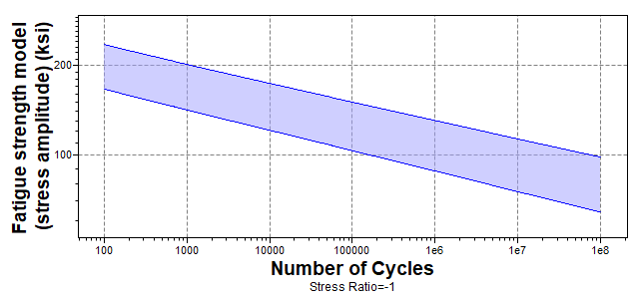
Carabiner material analysis
Team project · ME 331 Materials Science
Took an industrial carabiner and worked out what it would take to make it safe for climbing:
material selection, stress analysis, and a fatigue-life model for the loaded gate.
Carabiner model.Fatigue model, R = −1.
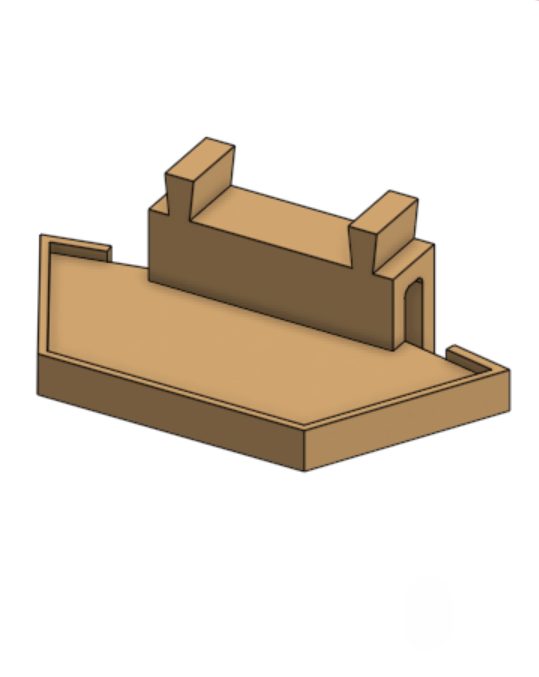
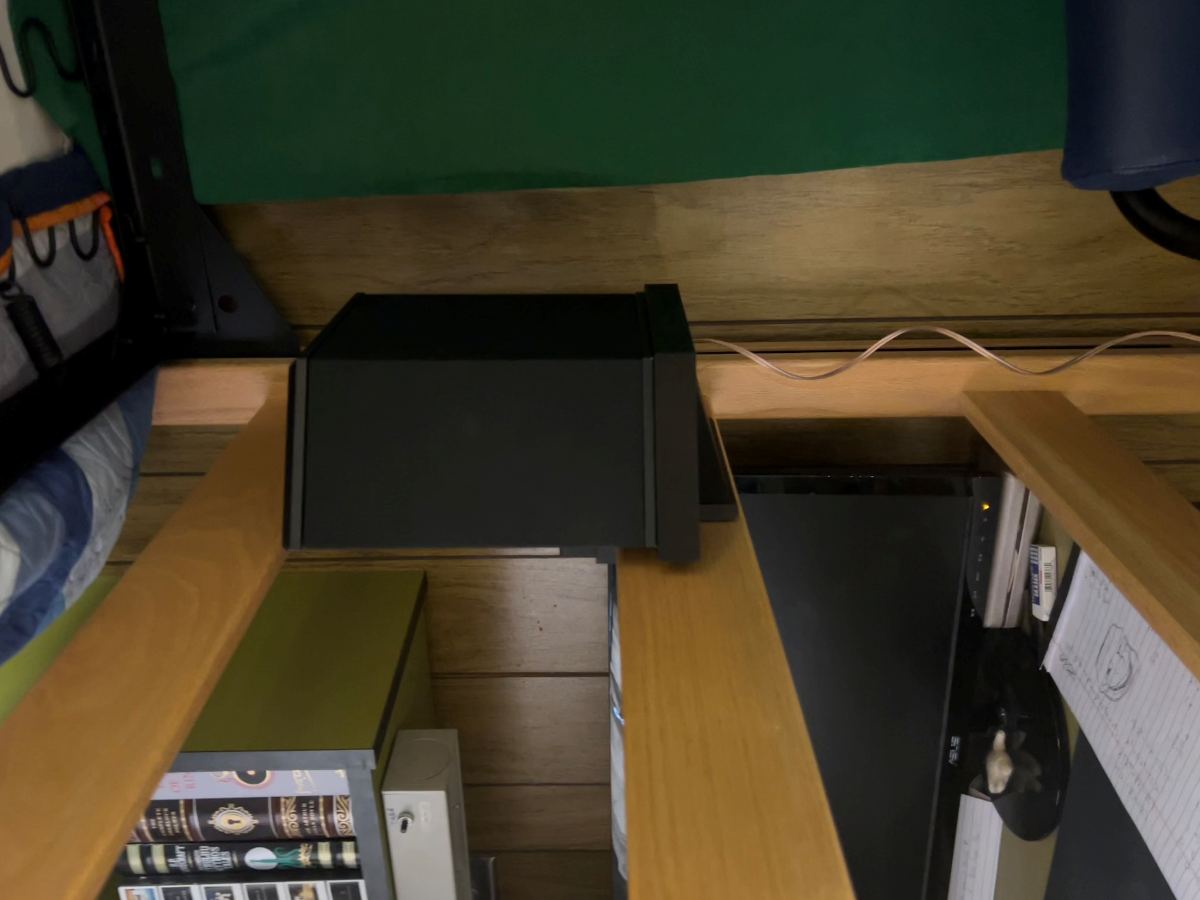
Dorm speaker mount
Solo · Onshape · FDM printing
A bracket that hooks onto the campus bed frame and holds a rear surround speaker, designed in
Onshape and printed on the NDSU library's 3D printers.
Bracket model.Installed.
On the bench: self-balancing cube, reaction-wheel balancing with LQR control on an ESP32.